
Data Capture
This chapter covers GNSS settings, project naming and scan settings, scanning, rendering modes, Scan Assist, model viewing, and data export.
GNSS Settings
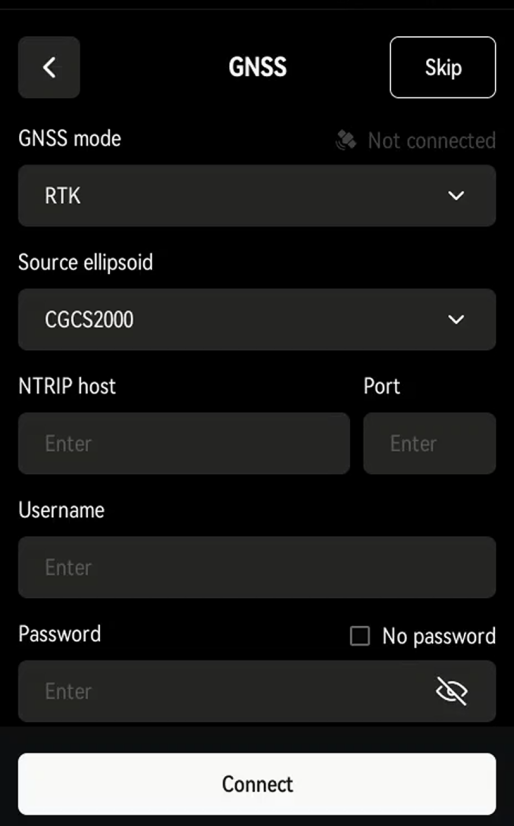
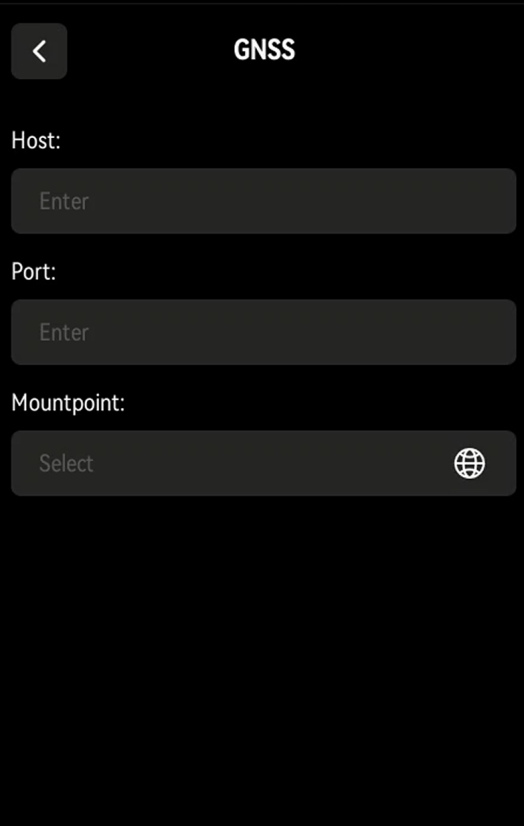
Tap GO to open GNSS settings.
Note
To skip GNSS, tap "Skip" in the upper-right corner, or turn off GNSS in Settings to skip this screen by default.
GNSS mode
| GNSS Mode | Function | How to Use |
|---|---|---|
| RTK | Receives correction data through the RTK module for real-time positioning; saved to the project file | Select RTK mode; process with the RTK module in LixelStudio |
| PPK | Records raw satellite observations through the RTK module; saved to the project file | Select PPK mode; process with the PPK module in LixelStudio |
RTK account management
Tap Connect to save frequently used accounts to the device. Manage them from the account list under GNSS Mode.
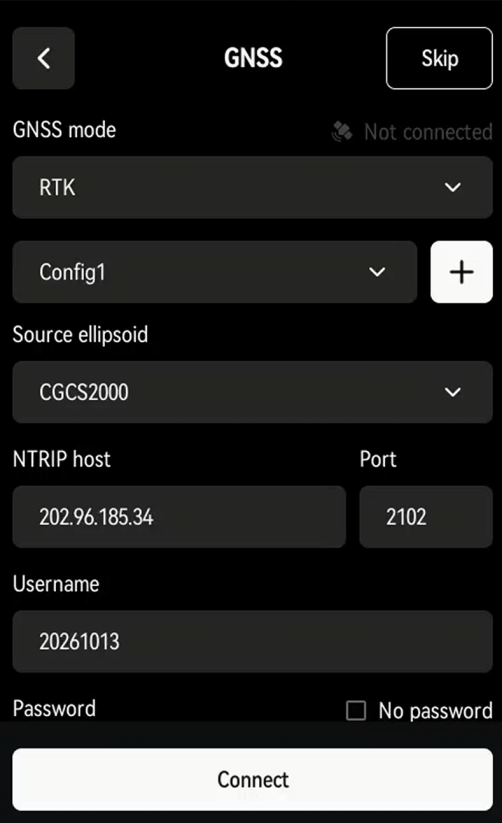
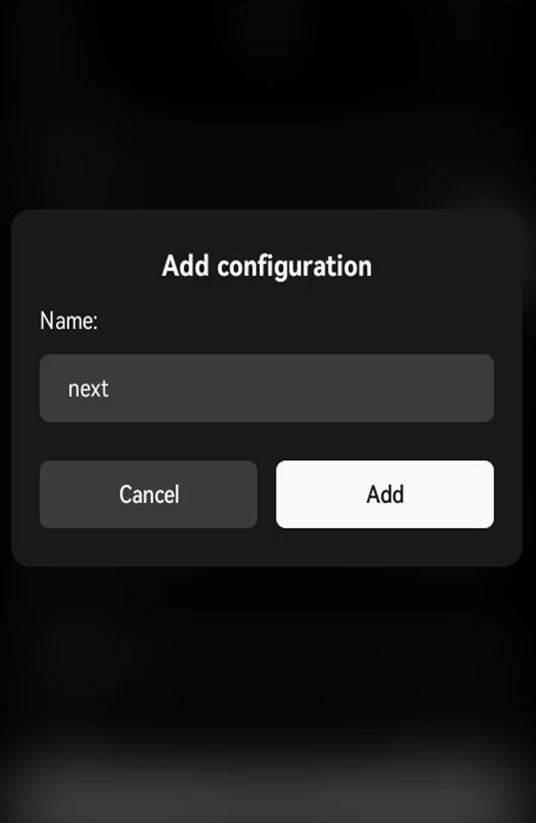
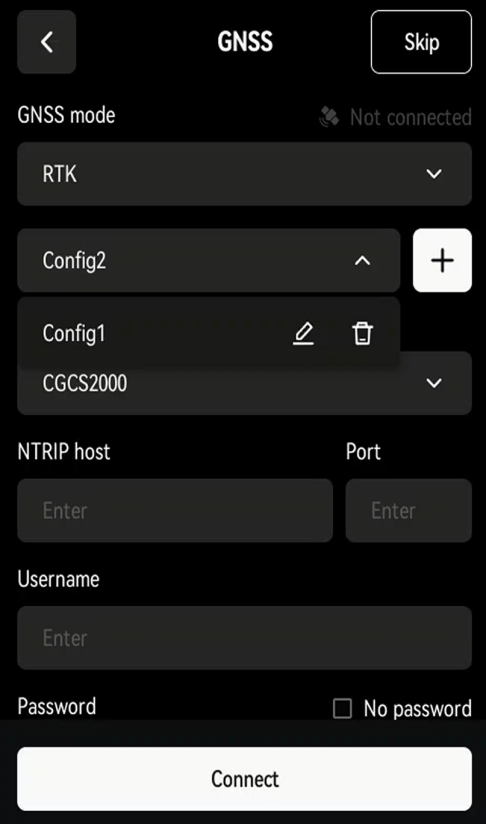
Note
- Custom RTK services must use a standard data format.
- After first setup, the device saves your RTK account and stays signed in until you disconnect.
- Disconnecting can take 1–2 minutes.
- Coordinate system changes take about 5 minutes to apply. Wait 5 minutes before starting work.
- The RTK module supports WGS 84, CGCS2000, and ITRF2008. Heights are ellipsoidal.
RTK status indicator
| Color | Status |
|---|---|
| Red | RTK not connected |
| Blue | RTK connected, not fixed |
| Green | RTK connected, fixed solution |
RTK connection status and satellites
Once connected, a confirmation appears and the "Connect" button changes to "Disconnect". RTK status and satellite count show in real time below Mountpoint. Tap Next.
Project Naming and Scan Settings
| Mounting Mode | Function | Description |
|---|---|---|
| Handheld | Handheld operation | LixelStudio reads the mounting mode automatically; no need to reselect it during processing |
Scan mode
| Mode | Function | Supported Rendering Modes |
|---|---|---|
| Guided mode | Evaluates scan quality in real time | Scan Assist and scan quality rendering; no true-color rendering |
| RGB mode | Shows the true-color point cloud in real time | True-color rendering; no Scan Assist or scan quality rendering |
Custom naming
Example: Enter "park" as the project name and start scanning. In USB storage mode, the project folder appears as "park_2026-01-15-1622026", where "2026-01-15-1622026" is the scan time.
With no project name, the folder appears as default_2026-01-15-1622026.
Naming Assistant
Naming Assistant builds names in a "Name_Floor_Count" format, for example BlockA_1_1. In USB storage mode, the project folder appears as BlockA_1_1_2026-01-15-1622026.
Tap Done to open the start screen.
Start Scanning
Start the Device
- Place the Lixel L3, with the base mount attached, on stable, level ground.
- On the start screen, press and hold anywhere to start scanning.
- The LiDAR starts spinning, the indicator flashes green rapidly, and a startup tone plays. The device then enters static initialization.
- Keep the device still until initialization completes. A tone plays and normal scanning begins.
- Slowly lift the scanner, then slowly detach the base mount, and begin scanning.
Recommended Handheld Posture
- Goal: Keep your body out of the camera view for better colorization.
- Recommended: Hold the device out in front of your chest.
- Avoid: Holding the device against your body.
Scan Route Recommendations
Lighting
- Choose even lighting.
- Avoid strong contrast between light and shadow.
Field of view
- Prefer open routes (such as the middle of a road) for better color coverage and accuracy.
Narrow spaces (such as gaps between buildings or alleys)
- Walk slower than normal.
- Wait for people and moving objects to clear.
- This keeps the point cloud accurate and well colorized.
Notice
Narrow spaces are harder to capture well. Take your time.
Rendering Mode
Tap "Rendering Mode" in the lower-right corner of the screen to switch display modes:
| Mode | Description |
|---|---|
| EL Elevation | Colors points by height to show terrain |
| RGB True color | Shows true color for easy object identification |
| QUAL Scan quality | Shows point density in real time to check coverage |
Notice
Available modes depend on the scan mode (Guided or RGB). For RGB display, set the scan mode to "RGB mode" on the project start screen.
About scan quality display
- Purpose: Checks point cloud density to prevent rework from missed or sparse areas.
- Note: Does not indicate scan accuracy or LCC scan quality.
Switch to QUAL regularly while scanning to catch missed areas.
Scan Assist
Purpose
- Checks whether point cloud density meets the threshold.
- Prevents rework from missed or sparse areas.
Note
Does not indicate scan accuracy or LCC scan quality.
How to Use
- After starting a scan, tap "Scan Assist" below the stop button.
- The settings screen opens.
- Set the step distance for the site.
Notice
Match the step distance to scene complexity for complete coverage.
Stop Scanning
Press and hold the red button at the bottom center of the screen to save data.
Saving runs in two stages: storing the data, then generating a viewable point cloud model.
The point cloud model then opens automatically for on-site checking.
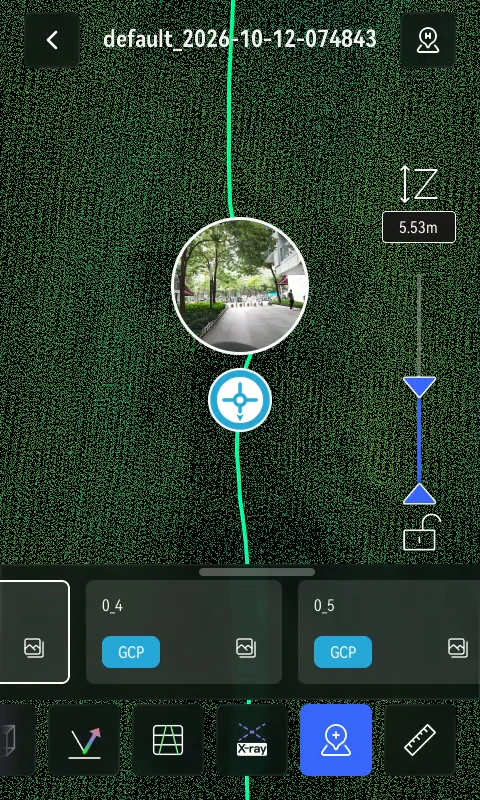
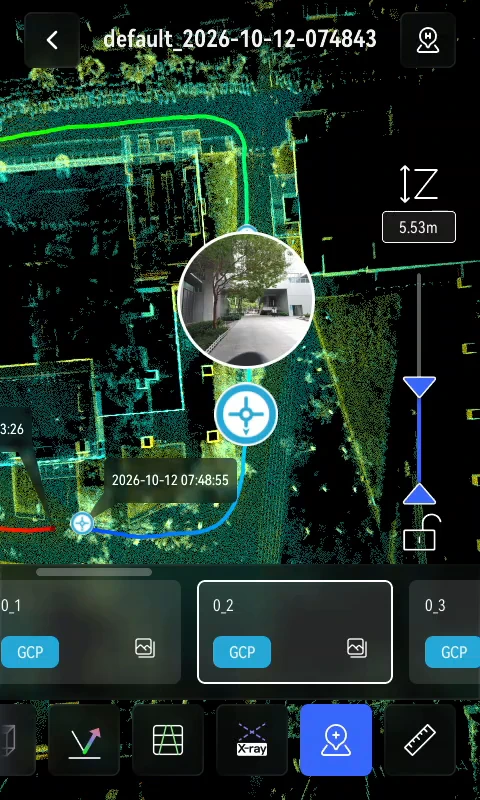
View Model
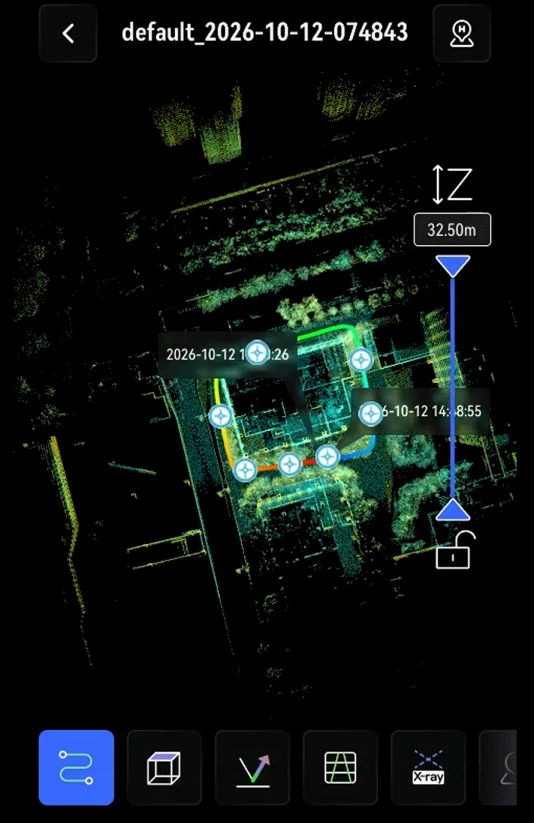
After scanning, view the point cloud model on the device screen.
View model
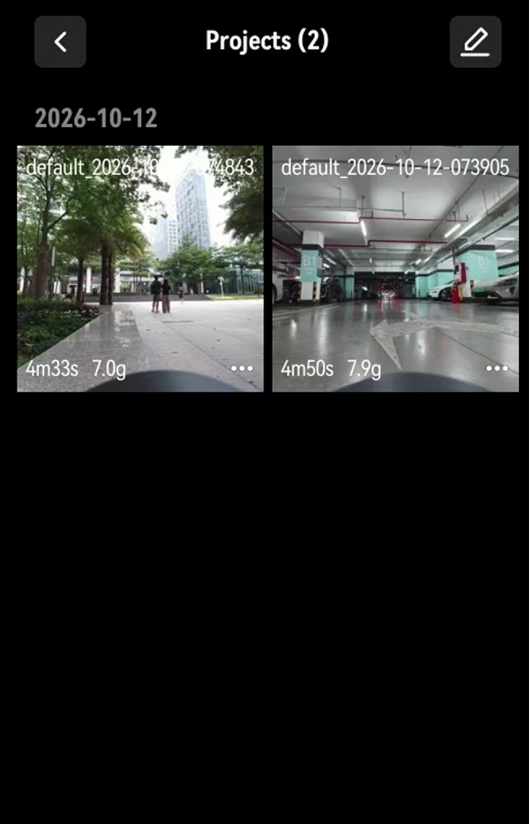
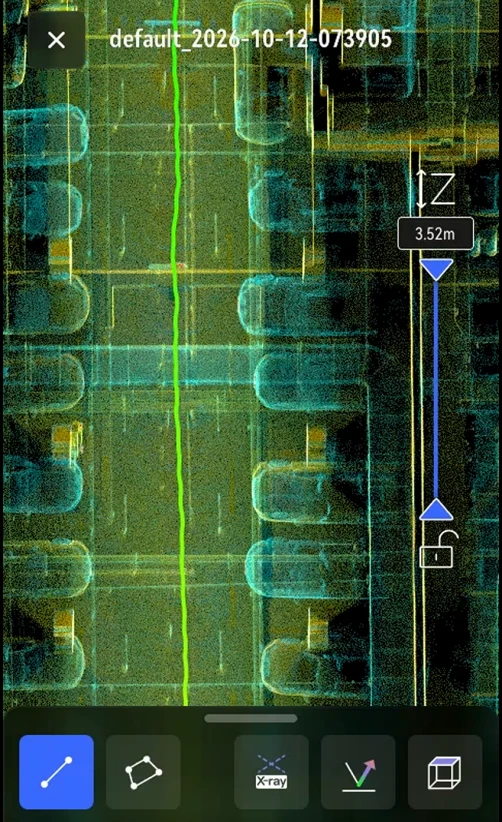
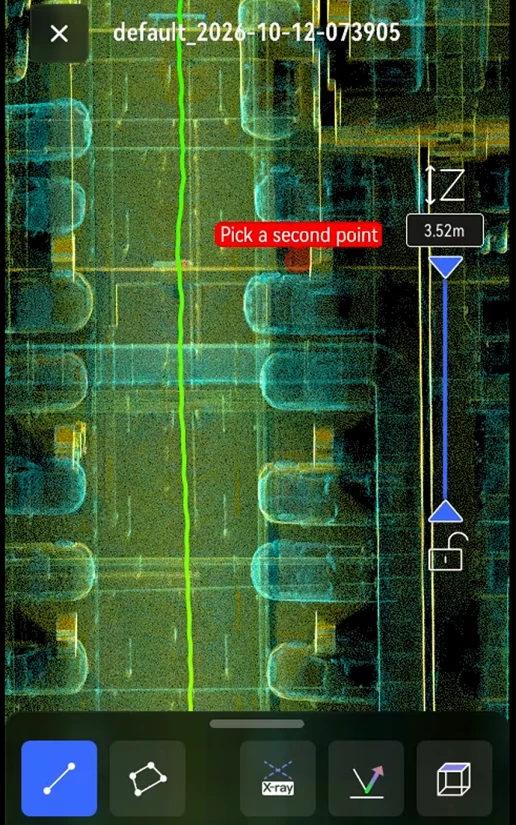
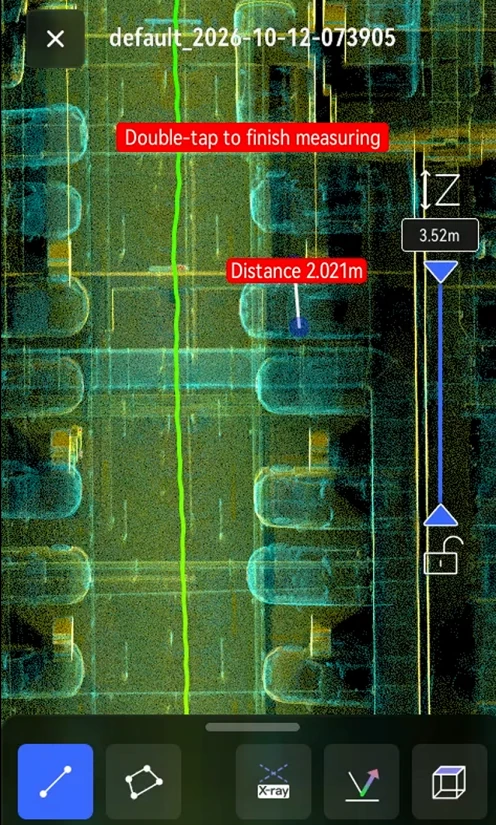
Measure
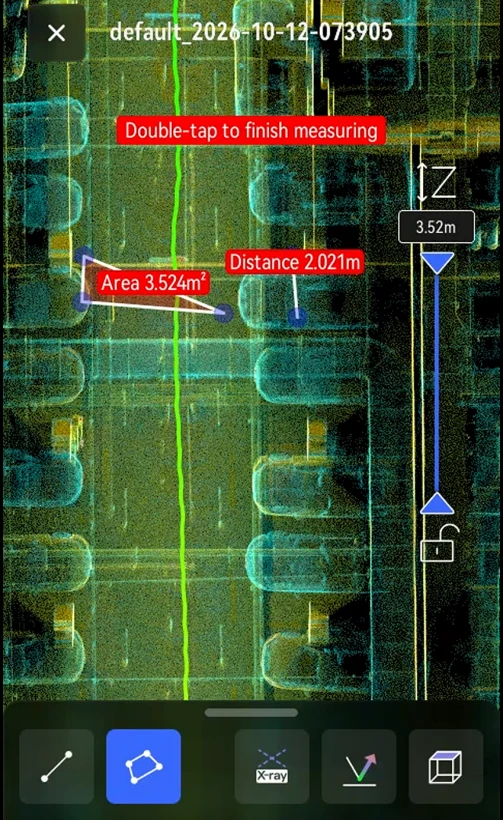
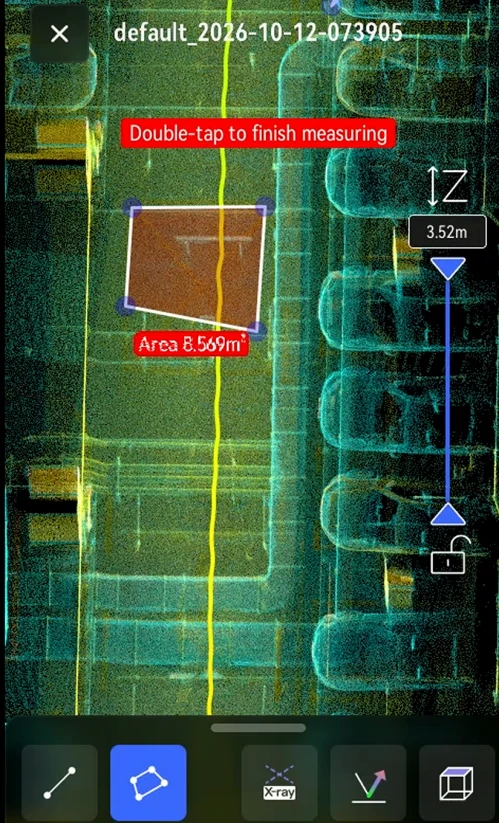
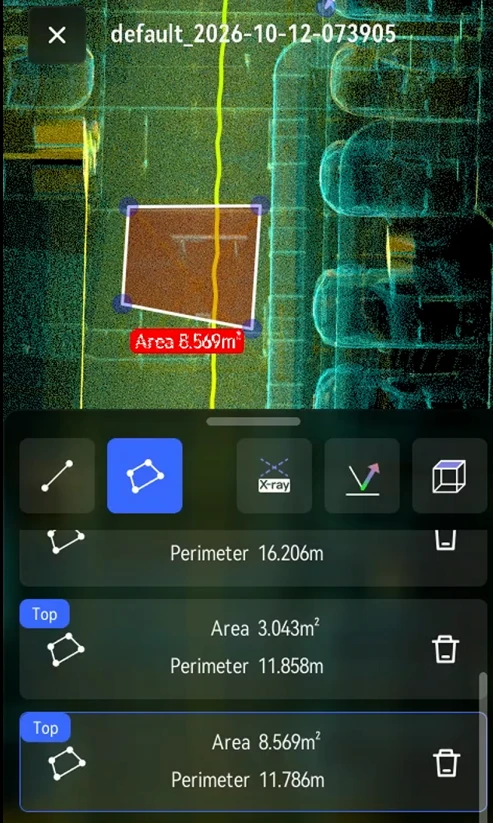
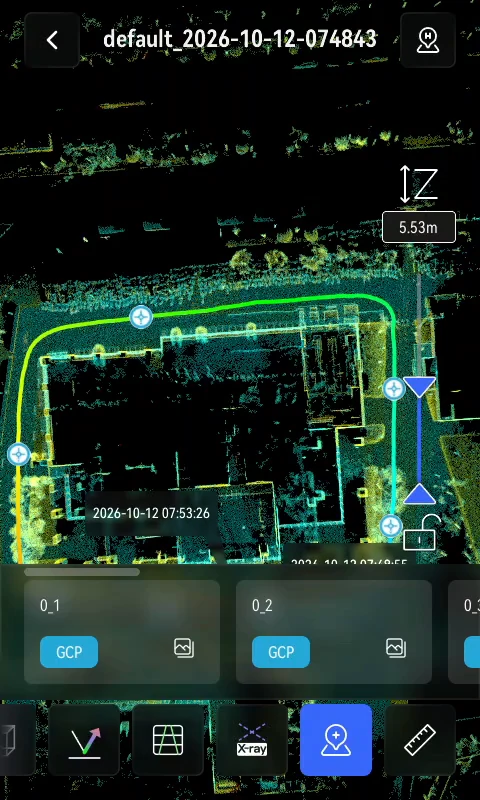
Point info
Export Scan Data
Steps
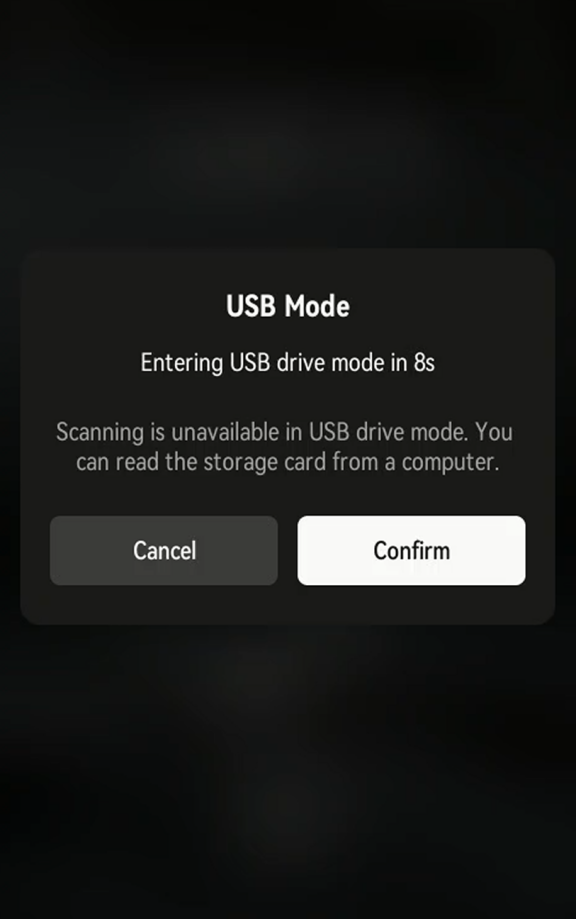
- Connect to a computer: Power on the device and connect it with a USB-C cable. Tap Confirm on the USB storage mode prompt, or wait for the countdown.
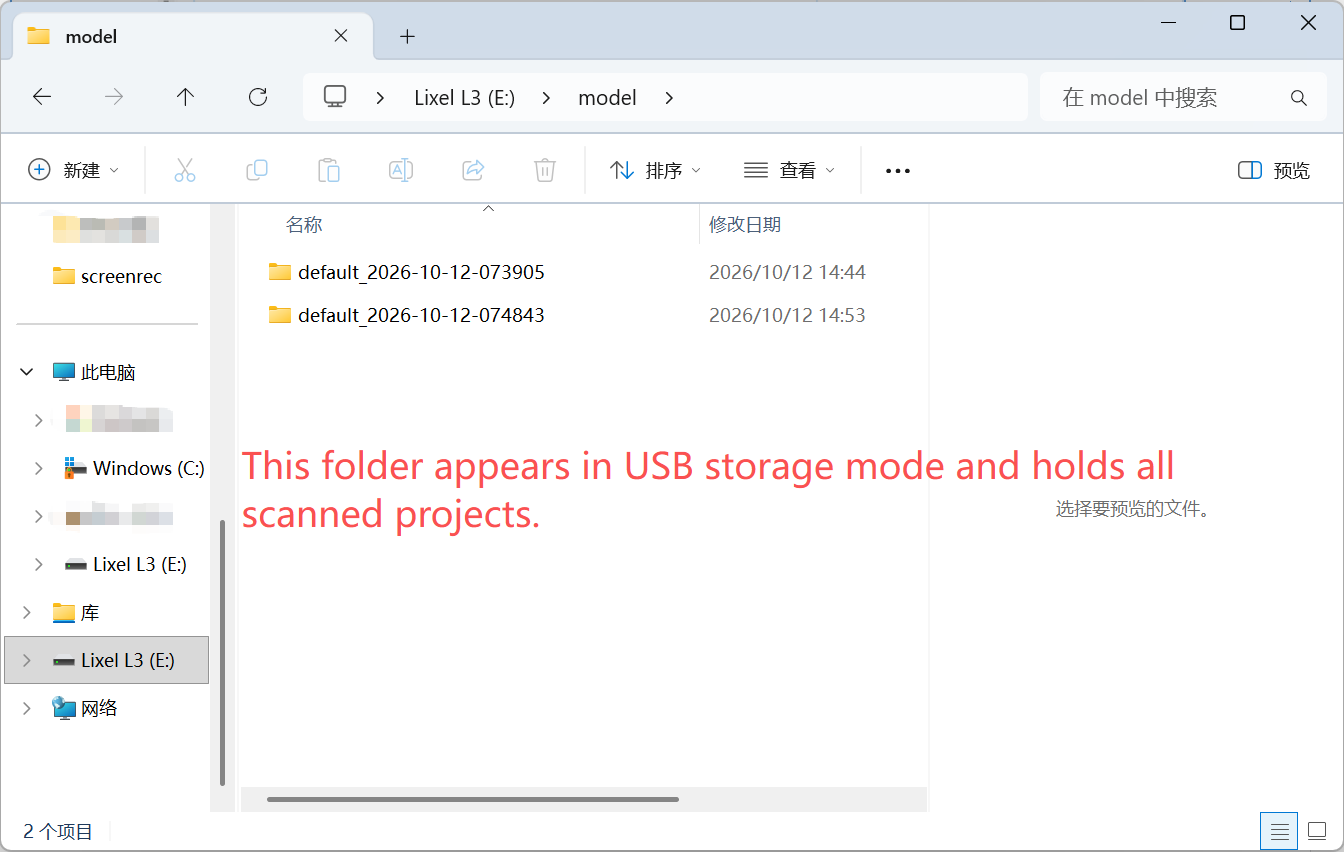
- Copy project files: Open the device storage, go to the model folder, and copy the project files to your computer.
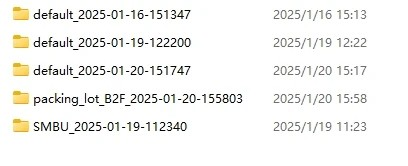
Project File Naming
File name format: ProjectName_YYYY-MM-DD-Time. Examples:
- ParkingB2F_2025-01-15-162026
- default_2025-01-15-143520
Notice
Files are named by scan start time for easy identification.
Project File Structure
Project files:
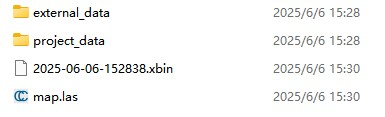
| File | Subfile | Description |
|---|---|---|
| xxx.xbin | - | Raw sensor data |
| map.las | - | Real-time point cloud from the device. |
| project_data | control_points.csv | Control point information recorded during the scan. |
| gnss.csv | GNSS data recorded when using RTK. | |
| poses.csv | Scan trajectory. | |
| photo | Camera images taken when control points are added | |
| model | Model preview files | |
| thumb.jpg | LixelGO preview image | |
| preview_photo.jpg | Device preview image | |
| log | Scan log | |
| external_data | - | Empty when first copied. Holds external files for LixelStudio post-processing, such as the coordinate-transformed gnss.csv. |